Robotics behind Pico
A robot combines sensing, computing and acting in a loop. Pico is a small social robot: it does not move, but it senses you, decides what to show and acts through its screen and speaker.
The loop Pico runs
Sense
Reads six buttons and receives agent requests over Wi-Fi.
Plan
Picks the face, message and sound for the request and its urgency.
Act
Draws on the screen, beeps and sends your answer back to the agent.
Improve
Testing with people tunes timing, sounds and how much text to show.
Inside the enclosure
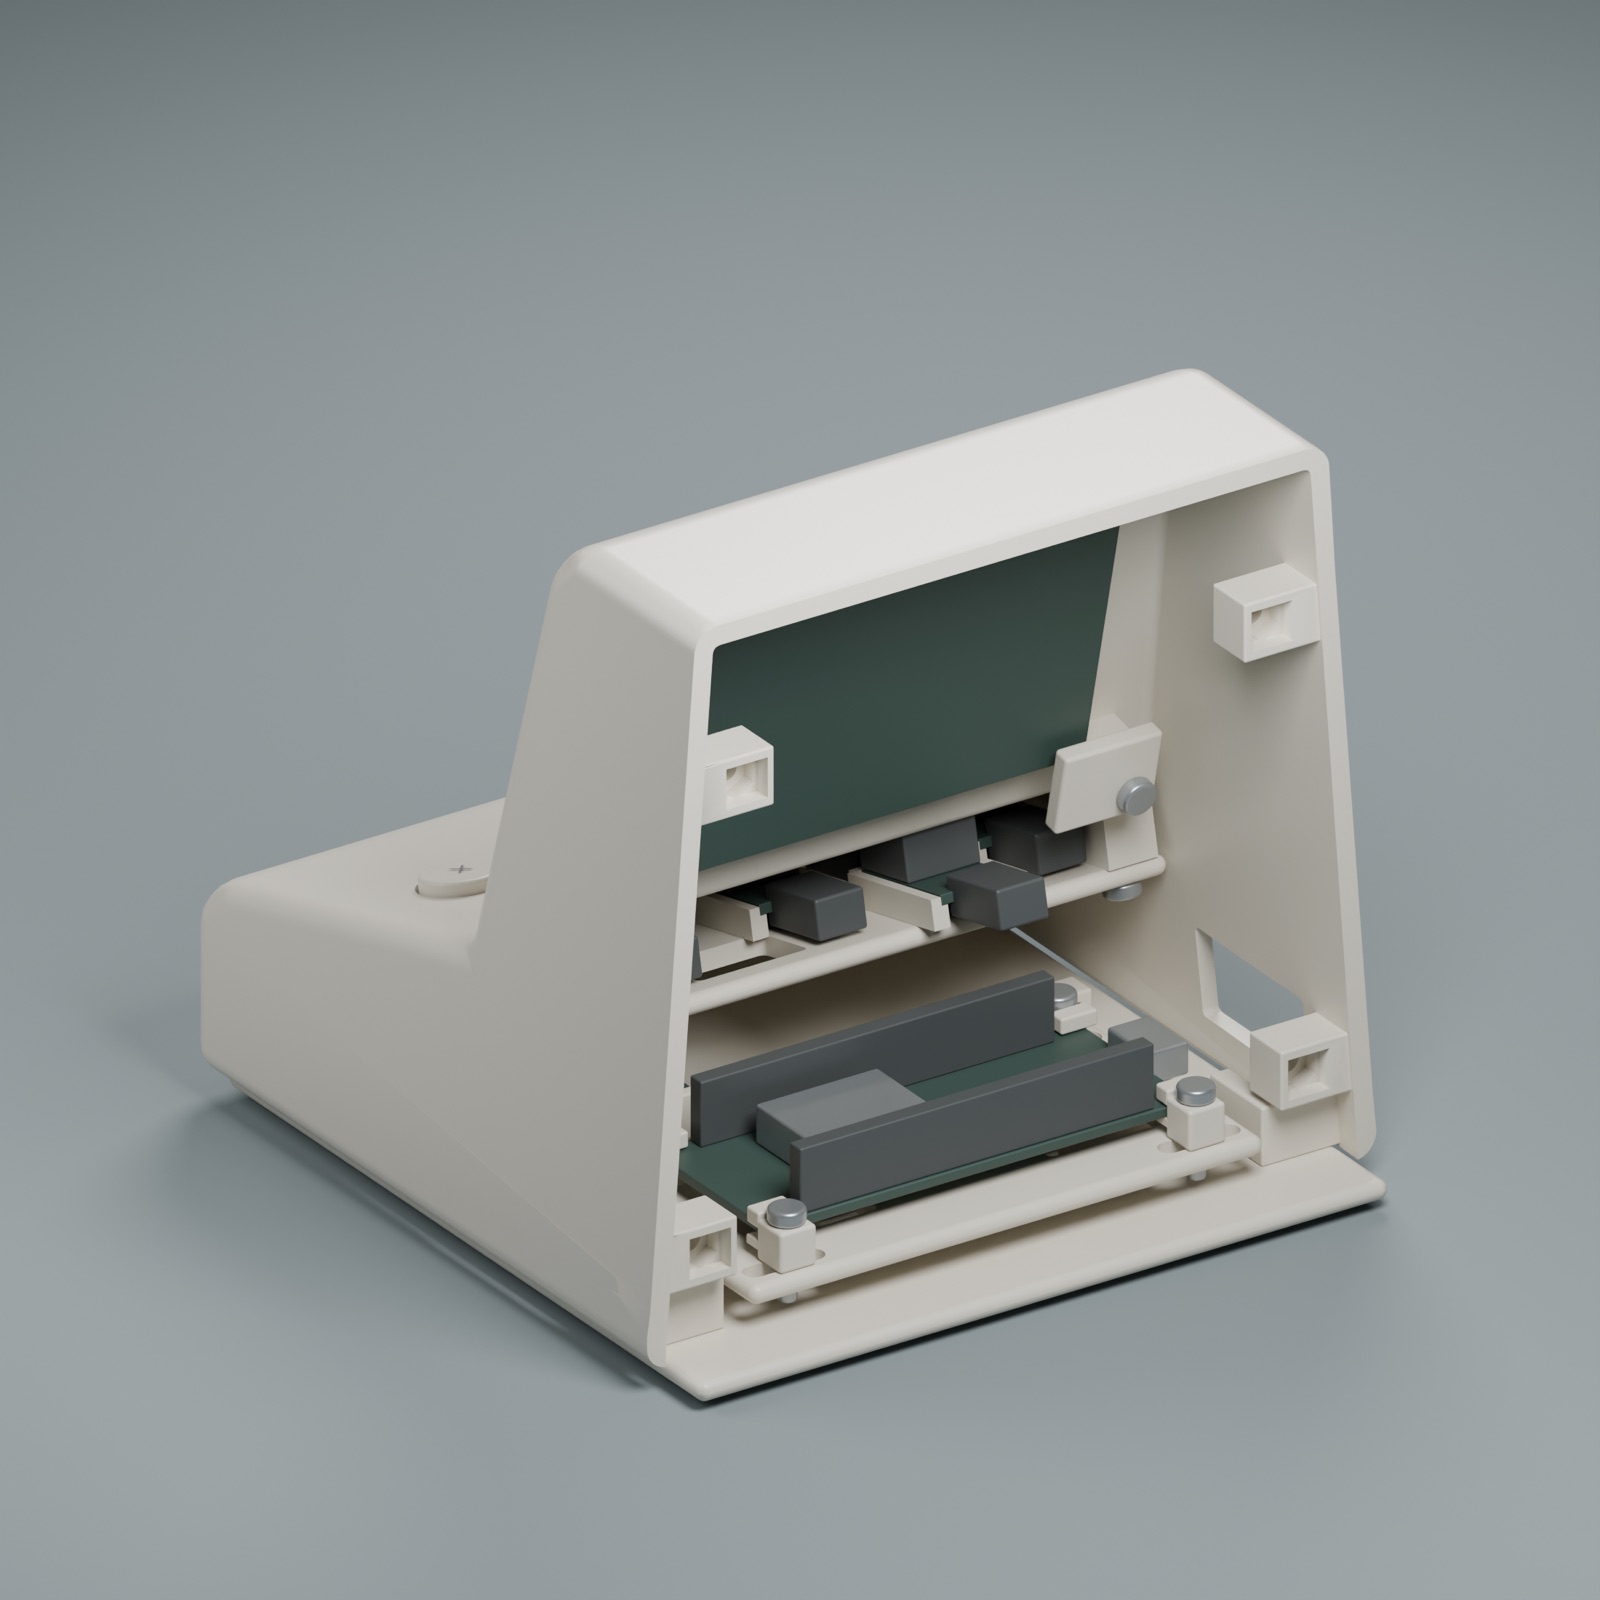
The ESP32-S3 sits on an adjustable sled in the bottom tray. The display is held by four clips behind the front window, and the six button modules sit on one carrier. A mini breadboard on the rear cover joins everything with jumper leads, so no soldering is needed.
The rear cover and bottom tray come off for service. Every part was checked in Blender for collisions and insertion paths, but not yet on a real printer.
Core ideas
Perception
How a robot knows what is happening. For Pico, that is button presses and incoming messages, not cameras.
Control
A state machine on the ESP32 moves between idle, working, waiting, approval needed, error and done.
Communication
Wi-Fi links Pico to the computer running the agent. Every request needs a reply, even on timeout.
Expression
Faces and sounds tell you the state before you read any text.
Types of robots
| Type | What it does |
|---|---|
| Industrial | Fixed arms that weld, paint and assemble in factories. |
| Service | Robots that do work for people, like cleaning or delivery. |
| Social | Robots built to communicate with people through faces, sound and gesture. Pico belongs here. |
| Mobile | Robots that move through a space, such as warehouse carts and delivery robots. |
| Autonomous | Robots that decide and act without step-by-step human control. |
| Humanoid | Robots shaped like people, to work in spaces made for people. |
| Surgical | Robots that give surgeons finer, steadier control. |
| Rescue | Robots that enter places too dangerous for people. |